Control:
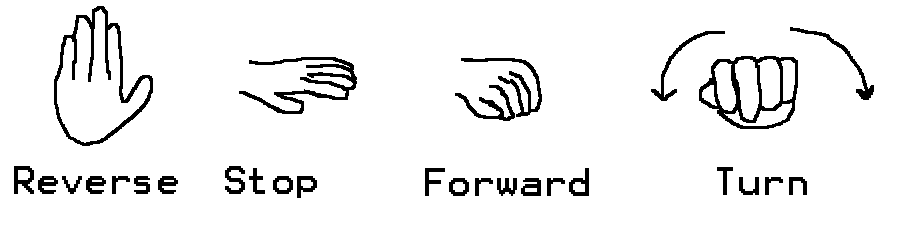
The Robot is controlled by an accelerometer mounted on the hand. The gestures used to controll the robot can be seen below.
-A fist will make the robot travel forward.
-A flat hand will make the robot stationary.
-Lift your hand so that it is perpendicular to the ground to make the traxster travel backward.
-rotate your fist left or right to make the robot turn accordingly.
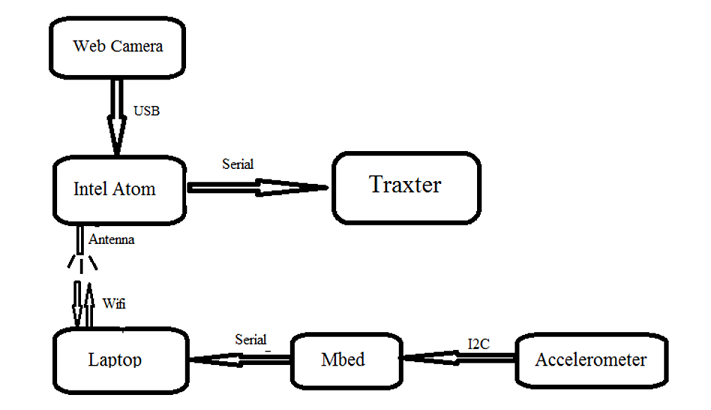
A block diagram describing the layout of the components described on the introduction page can be seen below as well.