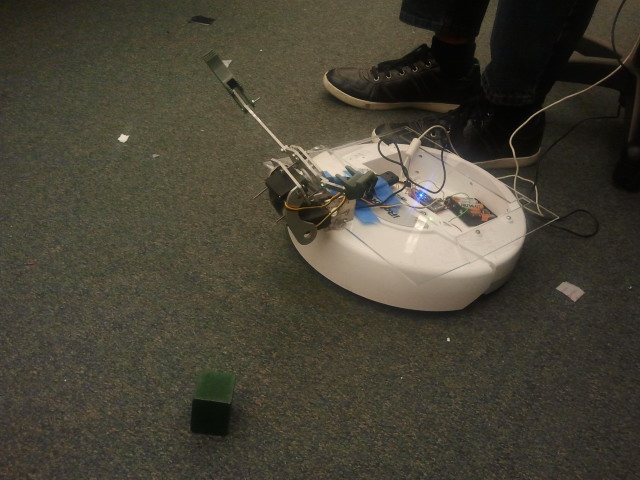
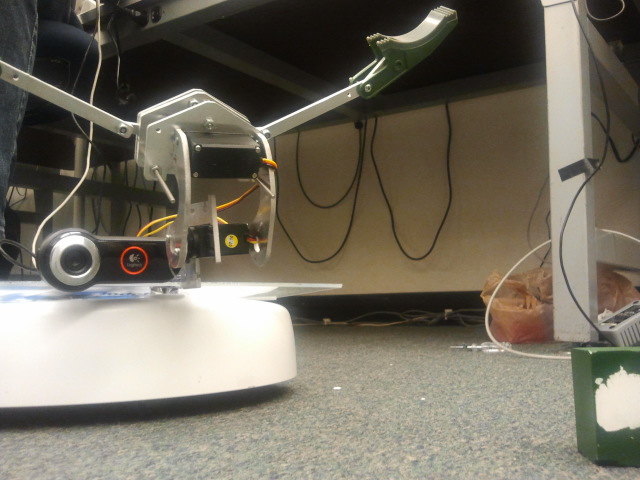
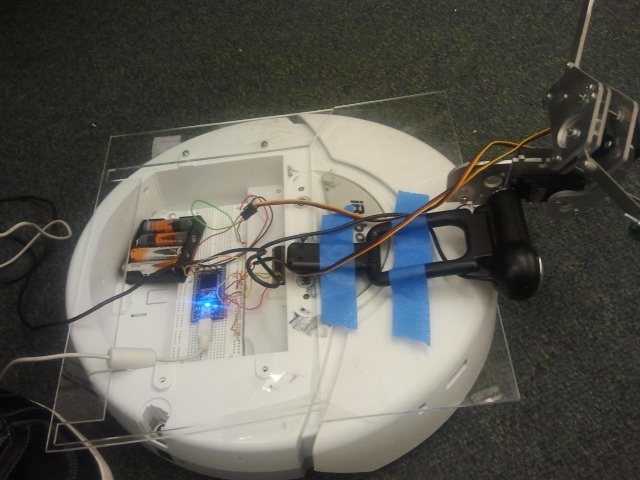
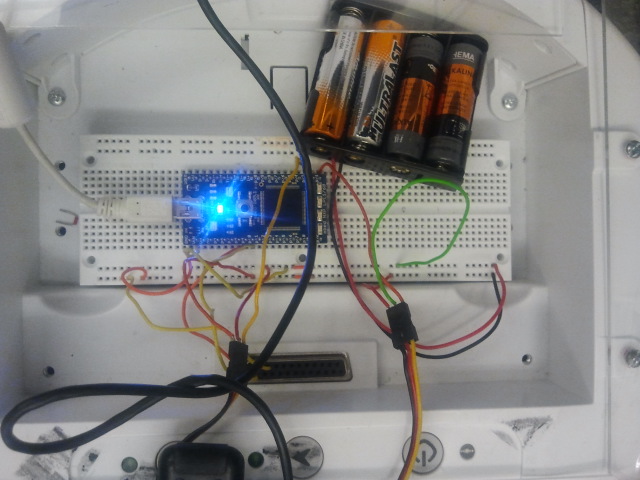
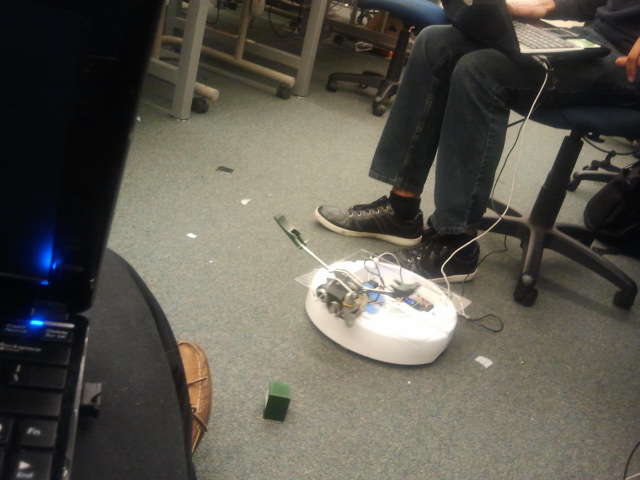
This project makes use of the iRobot Create Robot, claw, EasyVR, servo, webcam, and the RoboRealm.
iRobot
Robotic Inventory Management System
ECE4180 Dr. Hamblen
|
|
Project Goal:
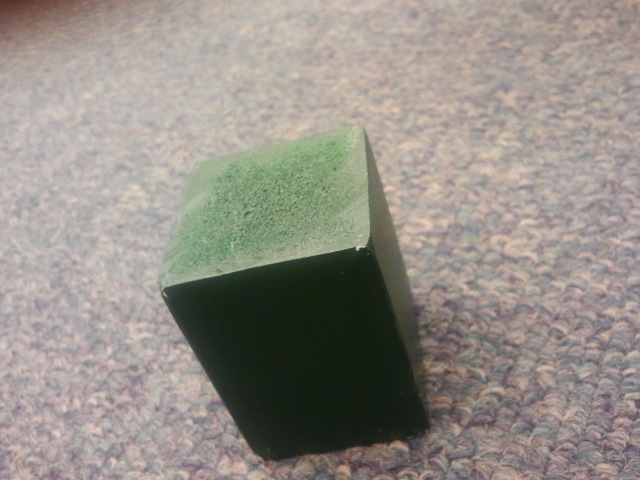
Using the EasyVR, a user would speak a color, "red", "blue", or "green" to indicate which of the three colored objects to look for. The mbed would control the iRobot and spin in a counterclockwise direction searching for the object with the webcam. The color filters from the RoboRealm API is used to detect the color requested. If not found, the robot would wait for another command, and if found, it would stop spinning with the object straight in front. The robot would proceed forward and a command for when to stop would be sent from the PC based on calculations received from the CoG (center of gravity) from the RoboRealm API for the distance. Once in proximity of the object, the robot would lower the claw arm, close the claw to hold the object, and lift the claw arm. From here, the robot would search for the yellow colored bin and proceed towards it using similar procedures mentioned previously for locating color and distance. The robot would bring the arm forward and release the object in the bin and retract the claw. After, the robot would reverse a little bit and restart the sequence.
Problems Encountered:
- Object detection: a fair amount of time was spent training the program to recognize the color of our block and nothing else. Based on the lighting of the room and background, sometimes the detection would pick up something other than our block.
- Claw: the claw took a fair amount of time to put together. Needed a light weight claw that would be able to pick up the object and not be too heavy for the servos.
- Once the code for the different parts of the project were put together, nothing worked like intended. Extensive debugging took a considerable amount of time to make sure the logic matched up.
Future Work:
We had custom commands for "red", "blue", "green", and "yellow" for the EasyVR working. We want to switch to a GUI that a user could operate that would be able to select the color and object. In addition to the selection, all available choices would be shown and an object from each color category could be selected and given a drop-down menu for the order of objects to retrieve.
We also wanted to be able to detect by shape (i.e. cone, ball, block) for each color.
Additional Supporting Documentation
Team Members: Carlton Beatty, Thomas Helton, Demerrick Moton