


|
Autonomous Object Retrieval Robot |
|
Team ELO |
|
Project Description |
|
The goal of the project is to build a robot that can autonomously retrieve a distinctly colored object when put into a room. For demonstration purposes, a red ball was used as the object of interest. |


|
Group members:
Yao Lu Zhiwei Chen Layton Balliet |
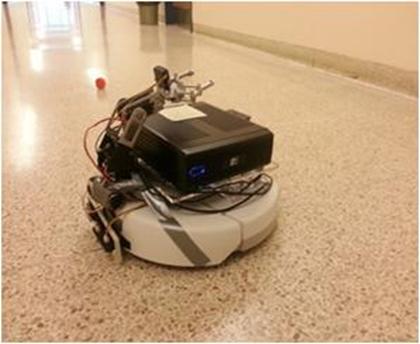
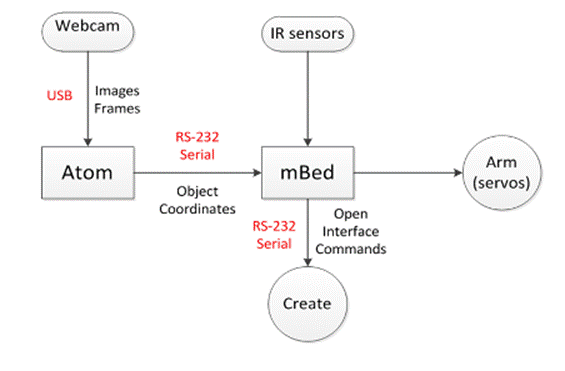
ApproachAutonomously guide robot with built in iRobot Create demos, identify distinctly colored object with OpenCV running on an Atom PC, and use a servo arm with claw to pick up the object System Overview |